Arseni Aliakseichyk
Embedded and Infrastructure Engineer
CyberGlove - IoT Smart Glove Platform
ESP32-S3 Wearable for Gesture Control
Personal • 2025 – Present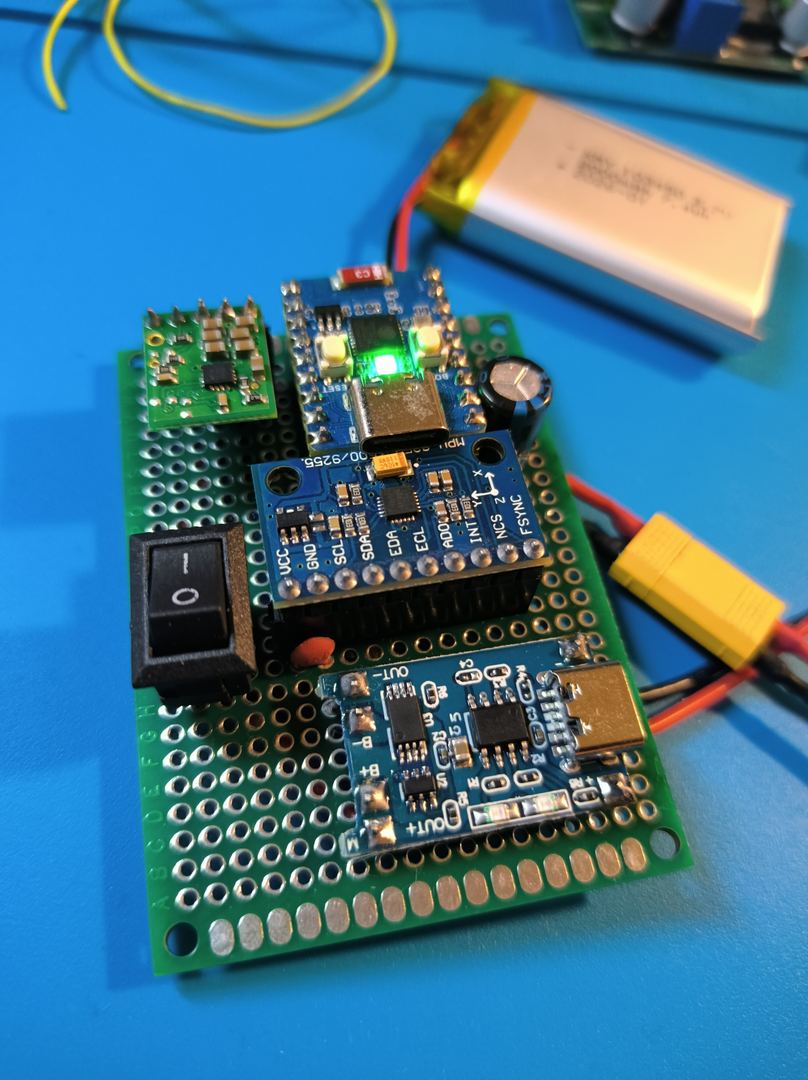
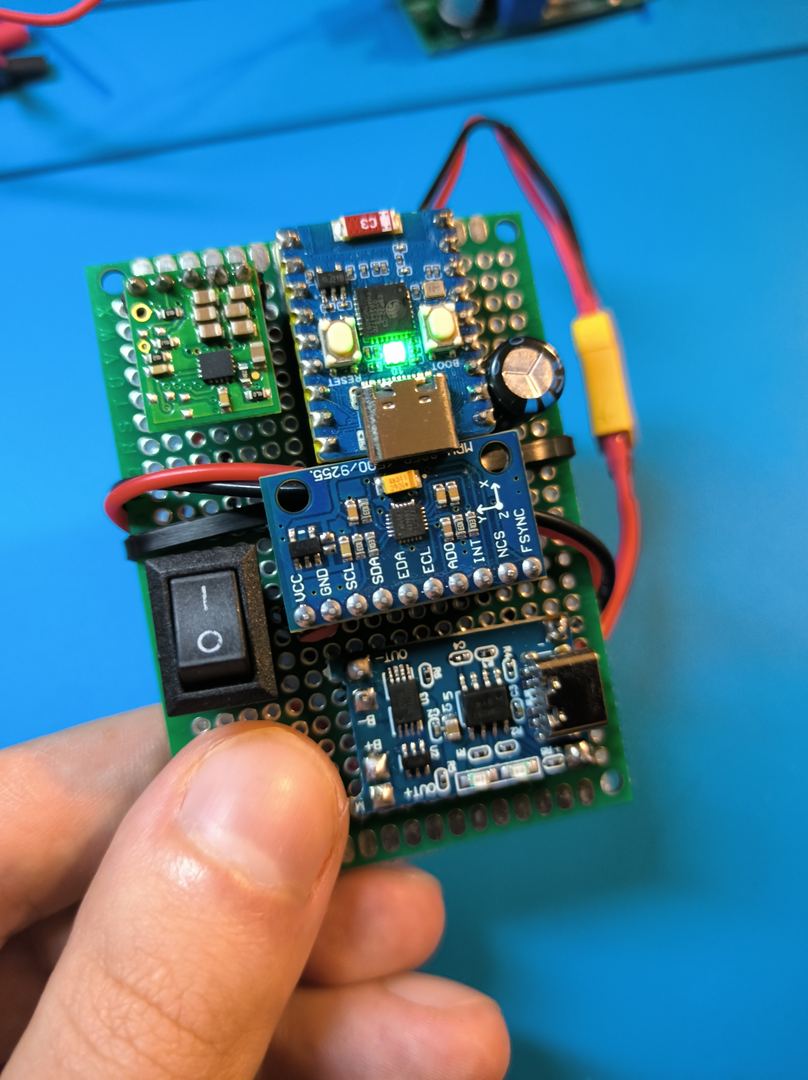
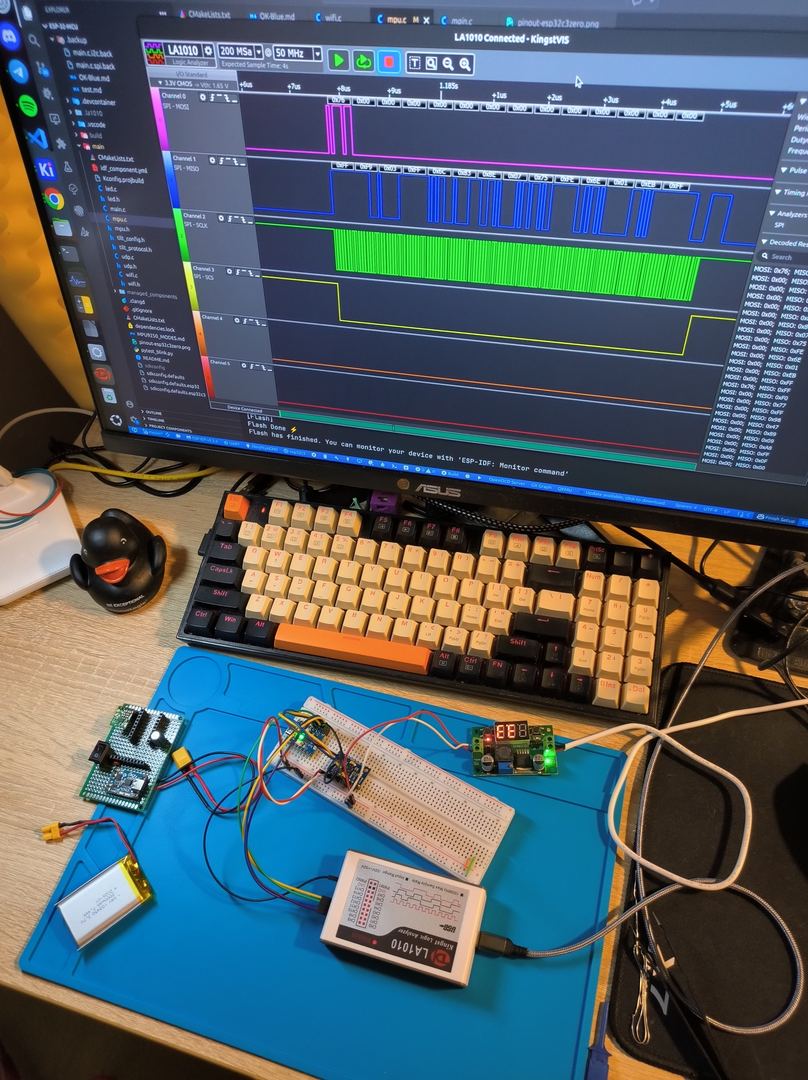
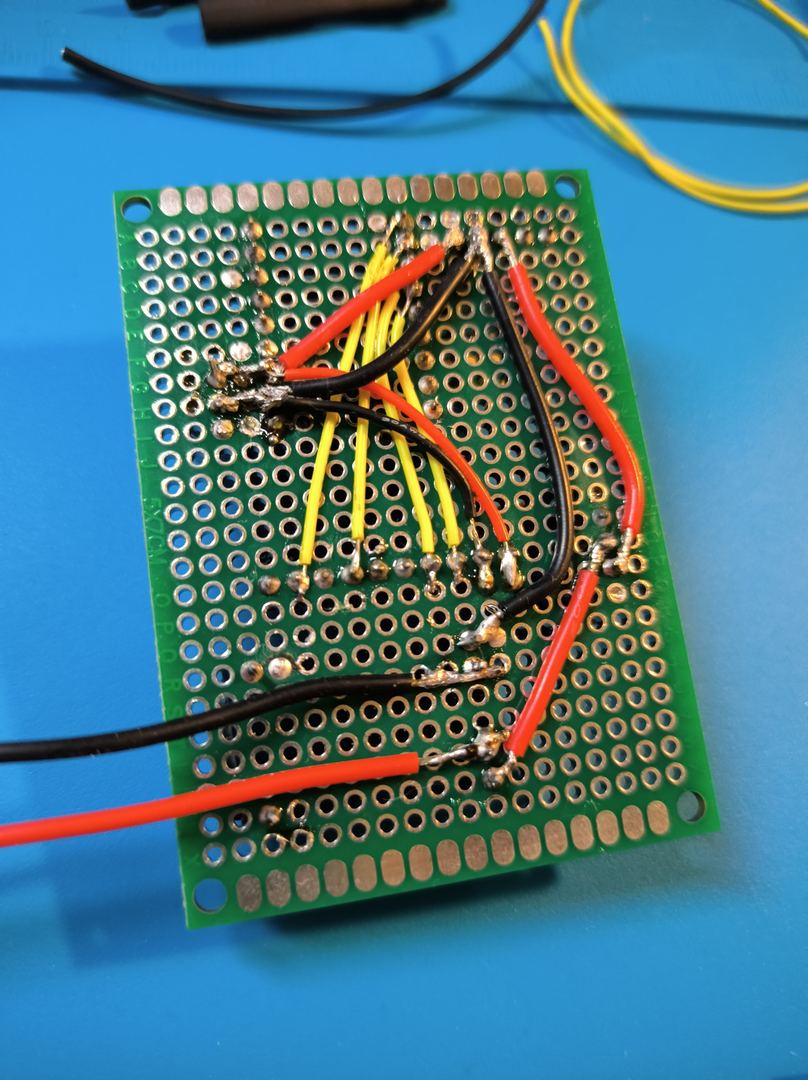
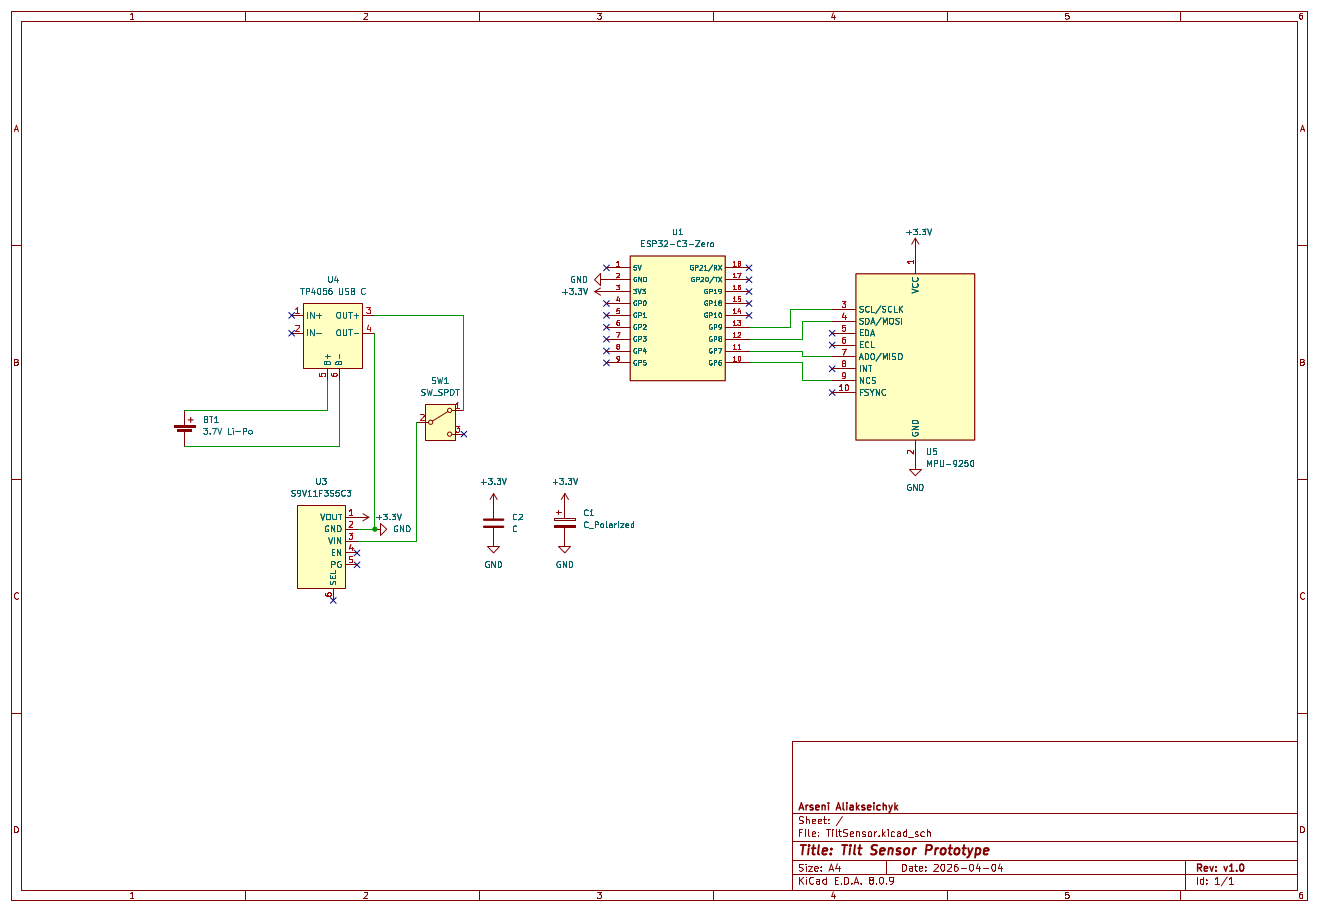
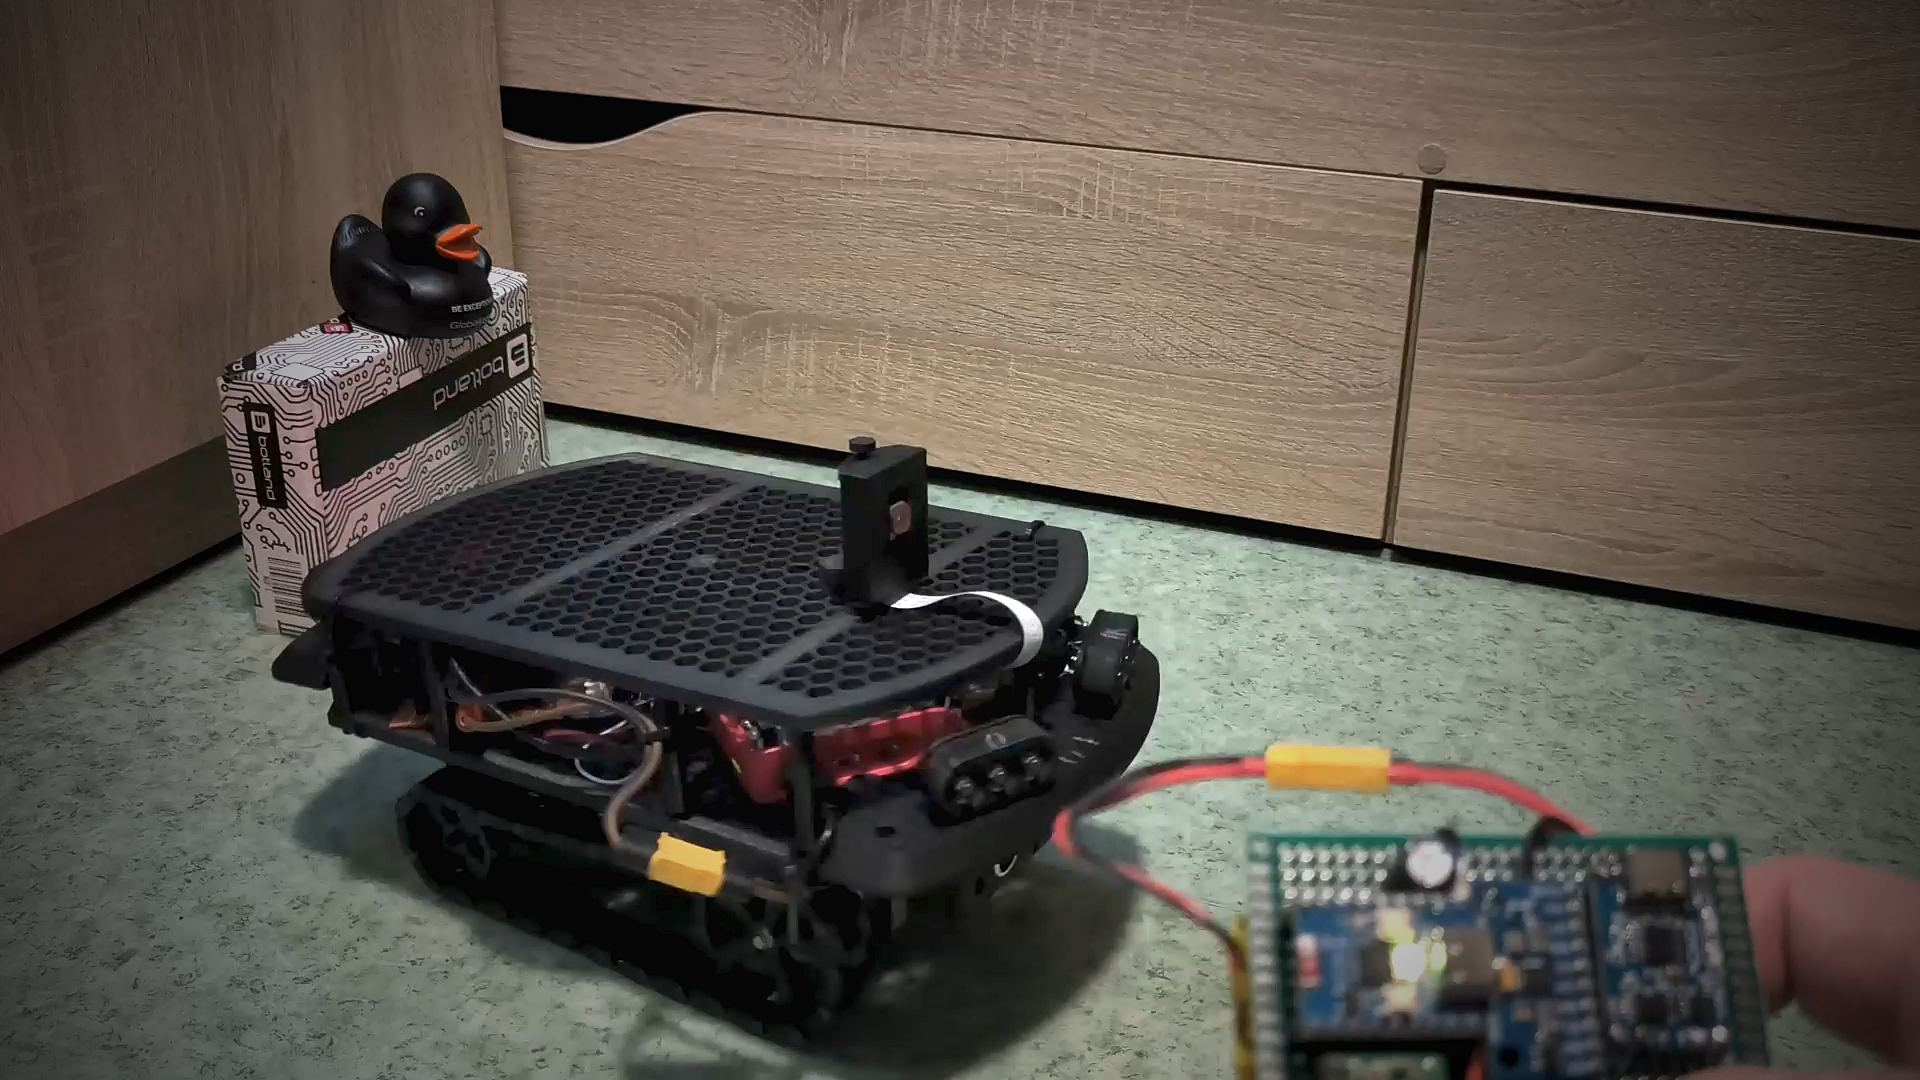
CyberGlove is my flagship personal project - an IoT smart glove for real-time gesture recognition and control, in active development. The current hardware is an ESP32-S3 with an ICM-20948 9-DoF IMU over SPI; the firmware is written in C on ESP-IDF with FreeRTOS, reads a custom fiber-optic bend sensor through the 12-bit ADC and streams sensor data at 50 Hz over WebSocket to a live web dashboard. Earlier prototypes (pictured) ran on an ESP32-C3-Zero with MPU-6050 and MPU-9250 IMUs. Each iteration was drafted in KiCad 8 (schematic, with the perfboard layout planned in the PCB Editor) and hand-soldered on perfboard with SMD and through-hole parts and a full LiPo power chain (TP4056 USB-C charger → S9V11F3S5C3 buck-boost 3.3V regulator + SPDT power switch). KiCad here is a drafting and layout-planning tool - full multilayer PCB fabrication is an experiment I’m still exploring. The Phase 1 sensor node was validated in a real application - integrated into the robot platform as an IMU-based tilt controller - before moving to Phase 2. Phase 2 (in progress): fiber-optic bend sensors on all five fingers via ADC for full finger-curl detection, combined with IMU orientation, with planned on-device TinyML inference for gesture recognition.
Key Features - Phase 1 (complete)
- ICM-20948 9-DoF IMU over SPI on ESP32-S3 (accelerometer + gyroscope + magnetometer); earlier iterations on MPU-6050 and MPU-9250
- Custom fiber optic bend sensor via ADC oneshot driver (12-bit resolution)
- Real-time WebSocket telemetry at 50 Hz (JSON sensor data)
- Schematic + perfboard layout in KiCad 8 (Schematic + PCB Editor), hand-soldered on perfboard with a LiPo power chain
- LiPo power management: TP4056 USB-C charger + S9V11F3S5C3 buck-boost 3.3V
- Wi-Fi STA mode with event-driven automatic reconnection
- FreeRTOS task management for concurrent sensor reading and network I/O
- Validated on robot platform as IMU tilt controller (UDP → Raspberry Pi)
Phase 2 (in progress) Update May 2026
- Fiber optic bend sensors on 5 fingers via ADC
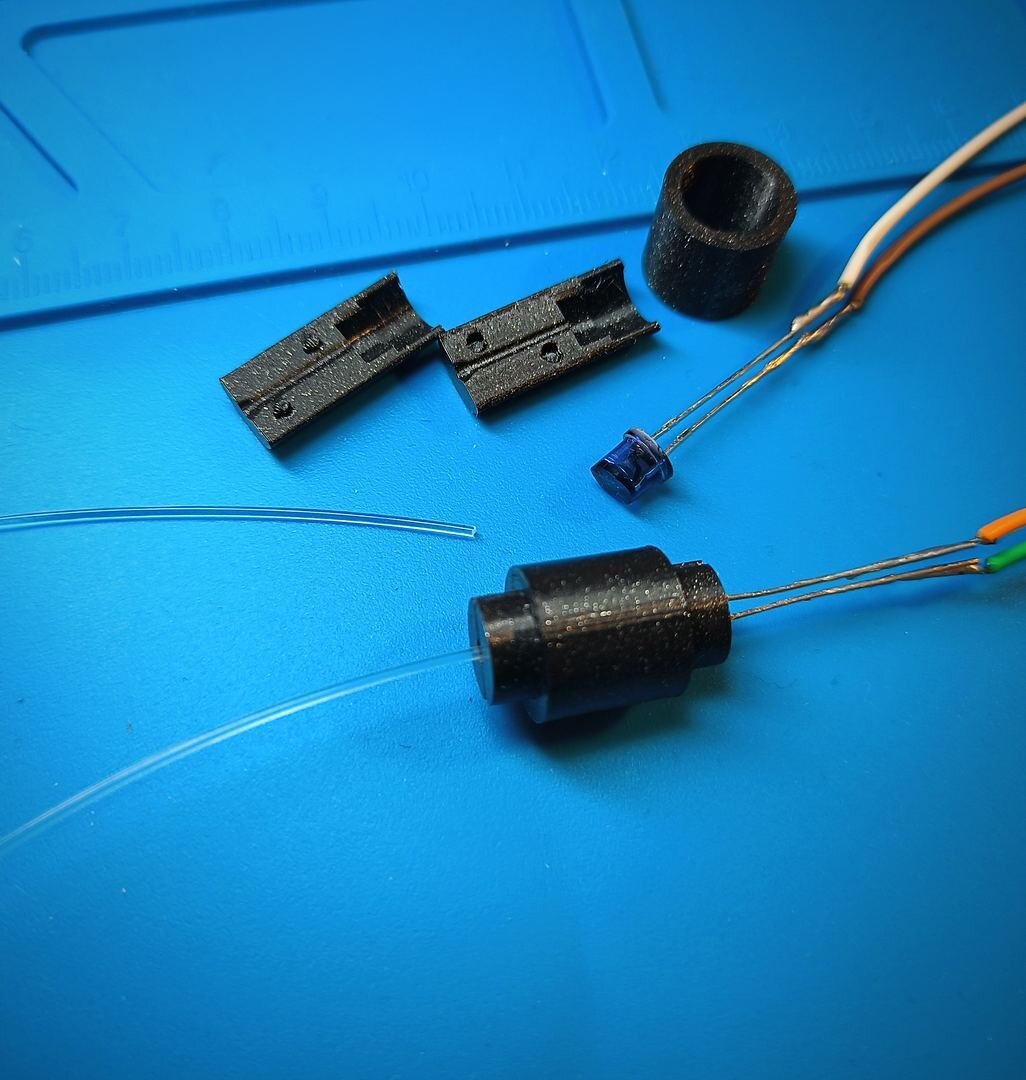
- Self-designed OpenSCAD 3D-printed optical fixture: split-clamshell housing aligning IR emitter LED, plastic optical fiber, and phototransistor with zero play for repeatable bend-sensor readings (printed in-house)
- Full gesture recognition combining finger curl + IMU orientation
- Planned TinyML on-device inference for custom gesture classification